Loading...
Searching...
No Matches
mrs_lib::LKF_MRS_odom Class Reference
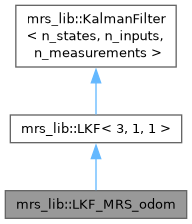
Inheritance diagram for mrs_lib::LKF_MRS_odom:
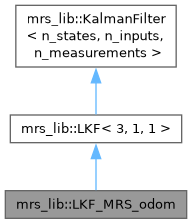
Collaboration diagram for mrs_lib::LKF_MRS_odom:
Public Types | |
| using | Base_class = LKF<n, m, p> |
| using | x_t = typename Base_class::x_t |
| using | u_t = typename Base_class::u_t |
| using | z_t = typename Base_class::z_t |
| using | P_t = typename Base_class::P_t |
| using | R_t = typename Base_class::R_t |
| using | statecov_t = typename Base_class::statecov_t |
| using | A_t = typename Base_class::A_t |
| using | B_t = typename Base_class::B_t |
| using | H_t = typename Base_class::H_t |
| using | Q_t = typename Base_class::Q_t |
| using | coeff_A_t = A_t |
| typedef Eigen::Matrix< unsigned, n, n > | dtexp_A_t |
| using | coeff_B_t = B_t |
| typedef Eigen::Matrix< unsigned, n, m > | dtexp_B_t |
| Public Types inherited from mrs_lib::LKF< 3, 1, 1 > | |
| using | Base_class |
| Base class of this class. | |
| using | x_t |
State vector type  | |
| using | u_t |
Input vector type  | |
| using | z_t |
Measurement vector type  | |
| using | P_t |
State uncertainty covariance matrix type  | |
| using | R_t |
Measurement noise covariance matrix type  | |
| using | Q_t |
| Process noise covariance matrix type | |
| using | statecov_t |
| Helper struct for passing around the state and its covariance in one variable. | |
| typedef Eigen::Matrix< double, n, n > | A_t |
| System transition matrix type | |
| typedef Eigen::Matrix< double, n, m > | B_t |
Input to state mapping matrix type  | |
| typedef Eigen::Matrix< double, p, n > | H_t |
State to measurement mapping matrix type  | |
| typedef Eigen::Matrix< double, n, p > | K_t |
Kalman gain matrix type  | |
| Public Types inherited from mrs_lib::KalmanFilter< n_states, n_inputs, n_measurements > | |
| typedef Eigen::Matrix< double, n, 1 > | x_t |
| State vector type | |
| typedef Eigen::Matrix< double, m, 1 > | u_t |
| Input vector type | |
| typedef Eigen::Matrix< double, p, 1 > | z_t |
| Measurement vector type | |
| typedef Eigen::Matrix< double, n, n > | P_t |
| State uncertainty covariance matrix type | |
| typedef Eigen::Matrix< double, p, p > | R_t |
| Measurement noise covariance matrix type | |
| typedef Eigen::Matrix< double, n, n > | Q_t |
| Process noise covariance matrix type | |
Public Member Functions | |
| LKF_MRS_odom (const std::vector< H_t > &Hs, const double default_dt=1) | |
| virtual statecov_t | predict (const statecov_t &sc, const u_t &u, const Q_t &Q, double dt) const override |
| x_t | state_predict_optimized (const x_t &x_prev, const u_t &u, double dt) const |
| P_t | covariance_predict_optimized (const P_t &P, const Q_t &Q, double dt) const |
| Public Member Functions inherited from mrs_lib::LKF< 3, 1, 1 > | |
| LKF () | |
| Convenience default constructor. | |
| virtual statecov_t | correct (const statecov_t &sc, const z_t &z, const R_t &R) const override |
| Applies the correction (update, measurement, data) step of the Kalman filter. | |
| virtual statecov_t | predict (const statecov_t &sc, const u_t &u, const Q_t &Q, double dt) const override |
| Applies the prediction (time) step of the Kalman filter. | |
| Public Member Functions inherited from mrs_lib::KalmanFilter< n_states, n_inputs, n_measurements > | |
| virtual statecov_t | correct (const statecov_t &sc, const z_t &z, const R_t &R) const =0 |
| Applies the correction (update, measurement, data) step of the Kalman filter. | |
| virtual statecov_t | predict (const statecov_t &sc, const u_t &u, const Q_t &Q, double dt) const =0 |
| Applies the prediction (time) step of the Kalman filter. | |
Static Public Attributes | |
| static const int | n = 3 |
| static const int | m = 1 |
| static const int | p = 1 |
| Static Public Attributes inherited from mrs_lib::LKF< 3, 1, 1 > | |
| static constexpr int | n |
| Length of the state vector of the system. | |
| static constexpr int | m |
| Length of the input vector of the system. | |
| static constexpr int | p |
| Length of the measurement vector of the system. | |
| Static Public Attributes inherited from mrs_lib::KalmanFilter< n_states, n_inputs, n_measurements > | |
| static const int | n = n_states |
| Length of the state vector of the system. | |
| static const int | m = n_inputs |
| Length of the input vector of the system. | |
| static const int | p = n_measurements |
| Length of the measurement vector of the system. | |
Additional Inherited Members | |
| Public Attributes inherited from mrs_lib::LKF< 3, 1, 1 > | |
| A_t | A |
| The system transition matrix | |
| B_t | B |
| The input to state mapping matrix | |
| H_t | H |
| The state to measurement mapping matrix | |
| Protected Member Functions inherited from mrs_lib::LKF< 3, 1, 1 > | |
| virtual K_t | computeKalmanGain (const statecov_t &sc, const z_t &z, const R_t &R, const H_t &H) const |
| std::enable_if< check >=0, statecov_t >::type | correction_impl (const statecov_t &sc, const z_t &z, const R_t &R, const H_t &H) const |
| Static Protected Member Functions inherited from mrs_lib::LKF< 3, 1, 1 > | |
| static P_t | covariance_predict (const A_t &A, const P_t &P, const Q_t &Q, const double dt) |
| static std::enable_if< check==0, x_t >::type | state_predict (const A_t &A, const x_t &x, const B_t &B, const u_t &u) |
| static R_t | invert_W (R_t W) |
The documentation for this class was generated from the following file:
- /home/runner/work/mrs_lib/mrs_lib/include/mrs_lib/lkf.h
